Part 1
요약·해설
Recessive/dominant state, open-drain drive, 120-ohm termination을 다룹니다.
CAN TX/RX · CAN H/L
recessive · dominant · wired-AND
Part 2
접을 수 있는 영어 원문 전체
영어 원문 전체 펼치기
90F4424F87D74F6A6DF421132E397B22322070DFE29CEA6B63D94ED159BA5332
.. _can_transceiver_api:

CAN Transceiver
###############

.. contents::
    :local:
    :depth: 2

Overview
********

A CAN transceiver is an external device that converts the logic level signals
from the CAN controller to the bus-levels. The bus lines are called
CAN High (CAN H) and CAN Low (CAN L).
The transmit wire from the controller to the transceiver is called CAN TX,
and the receive wire is called CAN RX.
These wires use the logic levels whereas the bus-level is interpreted
differentially between CAN H and CAN L.
The bus can be either in the recessive (logical one) or dominant (logical zero)
state. The recessive state is when both lines, CAN H and CAN L, are roughly at
the same voltage level. This state is also the idle state.
To write a dominant bit to the bus, open-drain transistors tie CAN H to Vdd
and CAN L to ground.
The first and last node use a 120-ohm resistor between CAN H and CAN L to
terminate the bus. The dominant state always overrides the recessive state.
This structure is called a wired-AND.

.. image:: ../../../../../hardware/peripherals/can/transceiver.svg
   :width: 70%
   :align: center
   :alt: CAN Transceiver

CAN Transceiver API Reference
*****************************

.. doxygengroup:: can_transceiver
Part 3
한국어 전문 번역
개요
CAN transceiver는 CAN controller의 logic-level signal을 bus level로 변환하는 external device입니다. Bus line은 CAN High(CAN H)와 CAN Low(CAN L), controller에서 transceiver로 보내는 wire는 CAN TX, 받는 wire는 CAN RX라고 합니다.
CAN TX/RX는 logic level을 사용하지만 bus level은 CAN H와 CAN L 사이의 differential voltage로 해석합니다. Bus는 recessive(logical 1) 또는 dominant(logical 0) 상태입니다.
Recessive는 CAN H와 CAN L이 거의 같은 voltage인 상태이며 idle 상태이기도 합니다. Dominant bit를 쓰면 open-drain transistor가 CAN H를 Vdd, CAN L을 ground에 연결합니다.
첫 node와 마지막 node는 CAN H와 CAN L 사이에 120-ohm resistor를 연결해 bus를 terminate합니다. Dominant state는 항상 recessive state를 덮으며 이 구조를 wired-AND라고 합니다.
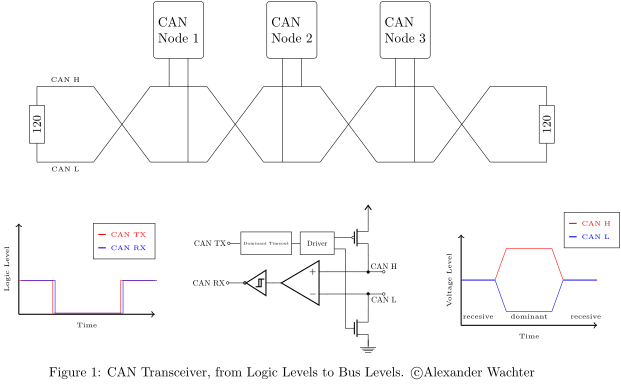
CAN transceiver API reference
can_transceiver Doxygen group이 CAN transceiver의 공식 API reference를 제공합니다.
Source
출처
영어 원문에는 문단, 문서 지시문, 표, 코드, 코드 심벌, 경로를 그대로 보존했습니다.