Part 1
요약·해설
M5StickC Plus component와 ESP-IDF·MCUboot 두 boot 흐름, 1,500,000bps flash를 다룹니다.
ESP32-PICO-D4 · 240MHz dual core
ST7789v2 · 135x240
MPU-6886 · SPM-1423 · BM8563
Part 2
접을 수 있는 영어 원문 전체
영어 원문 전체 펼치기
8CC1B05E05A335985477B57A9D2DD39EBF0C4D56088F1F3BEC50F0BE23CF83B7
.. _m5stickc_plus:

M5StickC PLUS
#############

Overview
********

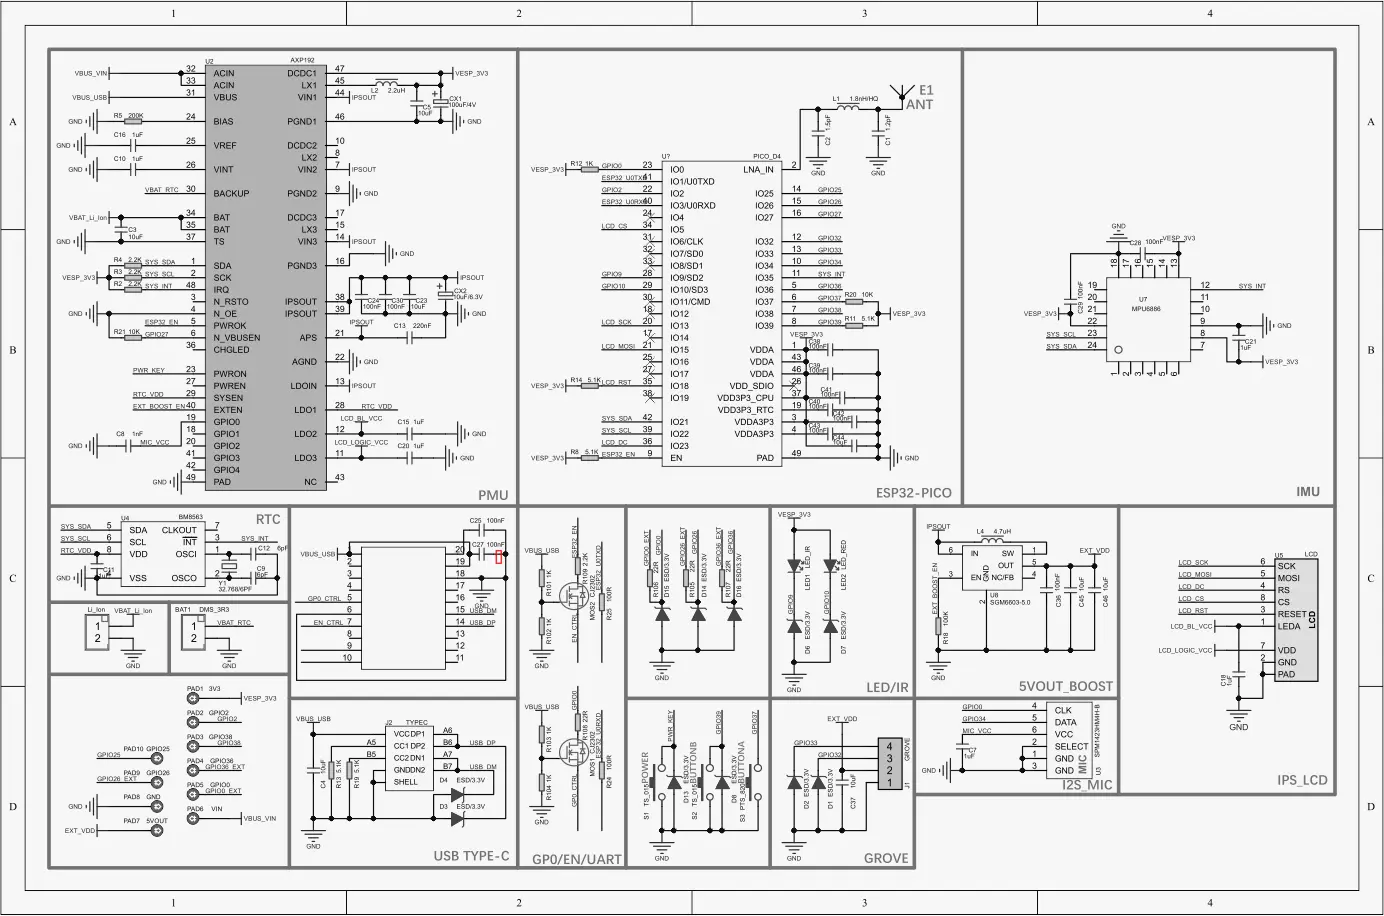
M5StickC PLUS, one of the core devices in M5Stacks product series, is an ESP32-based development board.

M5StickC PLUS features the following integrated components:

- ESP32-PICO-D4 chip (240MHz dual core, 600 DMIPS, 520KB SRAM, Wi-Fi)
- ST7789v2, LCD TFT 1.14", 135x240 px screen
- IMU MPU-6886
- SPM-1423 microphone
- RTC BM8563
- PMU AXP192
- 120 mAh 3,7 V battery

Some of the ESP32 I/O pins are broken out to the board's pin headers for easy access.

Functional Description
**********************

The following table below describes the key components, interfaces, and controls
of the M5StickC PLUS board.

.. _ST7789v2: https://m5stack.oss-cn-shenzhen.aliyuncs.com/resource/docs/datasheet/core/ST7789V.pdf
.. _MPU-6886: https://m5stack.oss-cn-shenzhen.aliyuncs.com/resource/docs/datasheet/core/MPU-6886-000193%2Bv1.1_GHIC_en.pdf
.. _ESP32-PICO-D4: https://m5stack.oss-cn-shenzhen.aliyuncs.com/resource/docs/datasheet/core/esp32-pico-d4_datasheet_en.pdf
.. _SPM-1423: https://m5stack.oss-cn-shenzhen.aliyuncs.com/resource/docs/datasheet/core/SPM1423HM4H-B_datasheet_en.pdf

+------------------+-------------------------------------------------------------------------+
| Key Component    | Description                                                             |
+==================+=========================================================================+
| 32.768 kHz RTC   | External precision 32.768 kHz crystal oscillator serves as a clock with |
|                  | low-power consumption while the chip is in Deep-sleep mode.             |
+------------------+-------------------------------------------------------------------------+
| ESP32-PICO-D4    | This `ESP32-PICO-D4`_ module provides complete Wi-Fi and Bluetooth      |
| module           | functionalities and integrates a 4-MB SPI flash.                        |
+------------------+-------------------------------------------------------------------------+
| Diagnostic LED   | One user LED connected to the GPIO pin.                                 |
+------------------+-------------------------------------------------------------------------+
| USB Port         | USB interface. Power supply for the board as well as the                |
|                  | communication interface between a computer and the board.               |
|                  | Contains: TypeC x 1, GROVE(I2C+I/O+UART) x 1                            |
+------------------+-------------------------------------------------------------------------+
| Power Switch     | Power on/off button.                                                    |
+------------------+-------------------------------------------------------------------------+
| A/B user buttons | Two push buttons intended for any user use.                             |
+------------------+-------------------------------------------------------------------------+
| LCD screen       | Built-in LCD TFT display \(`ST7789v2`_, 1.14", 135x240 px\) controlled  |
|                  | by the SPI interface                                                    |
+------------------+-------------------------------------------------------------------------+
| MPU-6886         | The `MPU-6886`_ is a 6-axis MotionTracking device that combines a       |
|                  | 3-axis gyroscope and a 3-axis accelerometer.                            |
+------------------+-------------------------------------------------------------------------+
| Built-in         | The `SPM-1423`_ I2S driven microphone.                                  |
| microphone       |                                                                         |
+------------------+-------------------------------------------------------------------------+


Start Application Development
*****************************

Before powering up your M5StickC PLUS, please make sure that the board is in good
condition with no obvious signs of damage.

System requirements
===================

Prerequisites
-------------

Espressif HAL requires WiFi and Bluetooth binary blobs in order work. Run the command
below to retrieve those files.

.. code-block:: console

   west blobs fetch hal_espressif

.. note::

   It is recommended running the command above after :file:`west update`.

Building & Flashing
*******************

ESP-IDF bootloader
==================

The board is using the ESP-IDF bootloader as the default 2nd stage bootloader.
It is build as a subproject at each application build. No further attention
is expected from the user.

MCUboot bootloader
==================

User may choose to use MCUboot bootloader instead. In that case the bootloader
must be build (and flash) at least once.

There are two options to be used when building an application:

1. Sysbuild
2. Manual build

.. note::

   User can select the MCUboot bootloader by adding the following line
   to the board default configuration file.

   .. code:: cfg

      CONFIG_BOOTLOADER_MCUBOOT=y

Sysbuild
========

The sysbuild makes possible to build and flash all necessary images needed to
bootstrap the board with the ESP32 SoC.

To build the sample application using sysbuild use the command:

.. zephyr-app-commands::
   :tool: west
   :app: samples/hello_world
   :board: m5stickc_plus
   :goals: build
   :west-args: --sysbuild
   :compact:

By default, the ESP32 sysbuild creates bootloader (MCUboot) and application
images. But it can be configured to create other kind of images.

Build directory structure created by sysbuild is different from traditional
Zephyr build. Output is structured by the domain subdirectories:

.. code-block::

  build/
  ├── hello_world
  │  └── zephyr
  │       ├── zephyr.elf
  │       └── zephyr.bin
  ├── mcuboot
  │    └── zephyr
  │       ├── zephyr.elf
  │       └── zephyr.bin
  └── domains.yaml

.. note::

   With ``--sysbuild`` option the bootloader will be re-build and re-flash
   every time the pristine build is used.

For more information about the system build please read the :ref:`sysbuild` documentation.

Manual build
============

During the development cycle, it is intended to build & flash as quickly possible.
For that reason, images can be build one at a time using traditional build.

The instructions following are relevant for both manual build and sysbuild.
The only difference is the structure of the build directory.

.. note::

   Remember that bootloader (MCUboot) needs to be flash at least once.

Build and flash applications as usual (see :ref:`build_an_application` and
:ref:`application_run` for more details).

.. zephyr-app-commands::
   :zephyr-app: samples/hello_world
   :board: m5stickc_plus/esp32/procpu
   :goals: build

The usual ``flash`` target will work with the ``m5stickc_plus`` board
configuration. Here is an example for the :ref:`hello_world`
application.

.. zephyr-app-commands::
   :zephyr-app: samples/hello_world
   :board: m5stickc_plus/esp32/procpu
   :goals: flash

The default baud rate for the M5StickC PLUS is set to 1500000bps. If experiencing issues when flashing,
try using different values by using ``--esp-baud-rate <BAUD>`` option during
``west flash`` (e.g. ``west flash --esp-baud-rate 115200``).

You can also open the serial monitor using the following command:

.. code-block:: shell

   west espressif monitor

After the board has automatically reset and booted, you should see the following
message in the monitor:

.. code-block:: console

   ***** Booting Zephyr OS vx.x.x-xxx-gxxxxxxxxxxxx *****
   Hello World! m5stickc_plus

Debugging
*********

M5StickC PLUS debugging is not supported due to pinout limitations.

Related Documents
*****************

- `M5StickC PLUS schematic <https://static-cdn.m5stack.com/resource/docs/products/core/m5stickc_plus/m5stickc_plus_sch_03.webp>`_ (WEBP)
- `ESP32-PICO-D4 Datasheet <https://www.espressif.com/sites/default/files/documentation/esp32-pico-d4_datasheet_en.pdf>`_ (PDF)
- `M5StickC PLUS docs <https://docs.m5stack.com/en/core/m5stickc_plus>`_
- `ESP32 Datasheet <https://www.espressif.com/sites/default/files/documentation/esp32_datasheet_en.pdf>`_ (PDF)
- `ESP32 Hardware Reference <https://docs.espressif.com/projects/esp-idf/en/latest/esp32/hw-reference/index.html>`_
Part 3
한국어 전문 번역
개요
M5StickC PLUS는 M5Stack product series의 core device 중 하나인 ESP32 development board입니다.
- ESP32-PICO-D4: 240MHz dual core, 600 DMIPS, 520KB SRAM, Wi-Fi
- ST7789v2 1.14-inch 135x240 LCD TFT
- MPU-6886 IMU, SPM-1423 microphone, BM8563 RTC, AXP192 PMU
- 120mAh 3.7V battery
ESP32 I/O pin 일부는 접근하기 쉽도록 pin header로 나옵니다.
기능 설명
| Key Component | Description |
|---|---|
| 32.768 kHz RTC | Deep-sleep에서 low-power clock으로 쓰는 external precision crystal oscillator입니다. |
| ESP32-PICO-D4 module | 완전한 Wi-Fi·Bluetooth 기능과 4-MB SPI flash를 제공합니다. |
| Diagnostic LED | GPIO pin에 연결된 user LED 1개입니다. |
| USB Port | 전원과 통신용 Type-C 1개 및 GROVE(I2C+I/O+UART) 1개입니다. |
| Power Switch | Power on/off button입니다. |
| A/B user buttons | User용 push button 2개입니다. |
| LCD screen | SPI로 제어하는 ST7789v2 1.14-inch 135x240 px LCD TFT입니다. |
| MPU-6886 | 3-axis gyroscope와 3-axis accelerometer를 결합한 6-axis MotionTracking device입니다. |
| Built-in microphone | I2S로 구동하는 SPM-1423 microphone입니다. |
Application development 시작
M5StickC PLUS에 전원을 넣기 전에 board 상태가 양호하고 눈에 띄는 손상이 없는지 확인하십시오.
Prerequisites
Espressif HAL용 WiFi·Bluetooth binary blob을 가져옵니다.
west blobs fetch hal_espressifBuilding과 Flashing
ESP-IDF bootloader
이 board는 ESP-IDF bootloader를 default 2nd-stage bootloader로 사용합니다. Application을 build할 때마다 subproject로 build되므로 사용자가 추가로 관리할 필요가 없습니다.
MCUboot bootloader
대신 MCUboot를 선택할 수 있으며 적어도 한 번 build하고 flash해야 합니다. Sysbuild 또는 Manual build를 사용할 수 있습니다.
CONFIG_BOOTLOADER_MCUBOOT=ySysbuild
ESP32 SoC bootstrap에 필요한 bootloader와 application image를 함께 build·flash합니다.
west build -b m5stickc_plus --sysbuild samples/hello_worldOutput은 domain subdirectory로 나뉩니다.
build/
├── hello_world
│   └── zephyr
│       ├── zephyr.elf
│       └── zephyr.bin
├── mcuboot
│   └── zephyr
│       ├── zephyr.elf
│       └── zephyr.bin
└── domains.yamlManual build
전통적인 build로 image를 하나씩 빠르게 만들 수 있습니다. Manual build와 sysbuild의 차이는 build directory 구조이며 MCUboot는 적어도 한 번 flash해야 합니다.
west build -b m5stickc_plus/esp32/procpu samples/hello_worldm5stickc_plus configuration의 일반적인 flash target을 사용합니다.
west build -b m5stickc_plus/esp32/procpu samples/hello_world
west flash
Default baud rate는 1500000bps입니다. 문제가 있으면 --esp-baud-rate <BAUD>를 사용하십시오. 예: west flash --esp-baud-rate 115200.
Serial monitor를 엽니다.
west espressif monitor자동 reset과 boot 뒤 예상 output입니다.
***** Booting Zephyr OS vx.x.x-xxx-gxxxxxxxxxxxx *****
Hello World! m5stickc_plus
Debugging
M5StickC PLUS는 pinout 제한 때문에 debugging을 지원하지 않습니다.
관련 문서
Source
출처
영어 원문에는 문단, 문서 지시문, 표, 코드, 코드 심벌, 경로를 그대로 보존했습니다.