Part 1
요약·해설
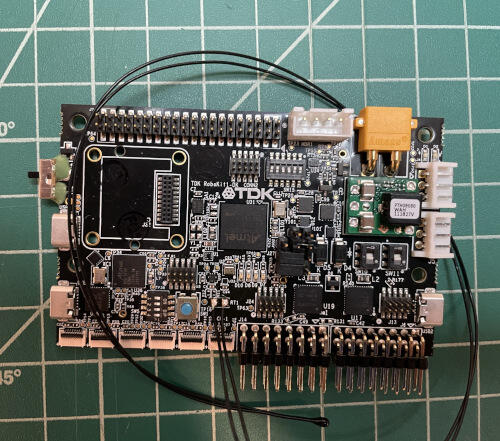
공식 이미지, 지원표 19행, sensor 전체와 3개 USB 연결·flash/debug 절차를 보존했습니다.
ATSAME70Q21
300MHz
IMU · ToF · audio
EDBG · OpenOCD
Part 2
접을 수 있는 영어 원문 전체
영어 원문 전체 펼치기
B91168A30C36247C1A5708F87F95CC7DE6EDAFC9F69A40ECB7E03E28C904C6B9
.. _robokit1:

TDK RoboKit 1
#############

Overview
********

The TDK RoboKit1 is a development board for use primarily with ROS2 and provides a large
number of small ground robotics useful sensors including chirp sensors for time of flight
(e.g. ultrasonic obstacle detection).

It pairs a 300MHz Cortex-M7 ATSAME70Q21 with an array of TDK sensors and pin headers useful for robotics.

.. image:: ../../../../../../../boards/tdk/robokit1/doc/img/tdk_robokit1.jpg
     :align: center
     :alt: TDK RoboKit1

Hardware
********

- ATSAME70Q21 ARM Cortex-M7 Processor
- 12 MHz crystal oscillator (Pres)
- 32.768 kHz crystal oscillator
- Micro-AB USB device
- Micro-AB USB debug (Microchip EDBG) interface supporting CMSIS-DAP, Virtual COM Port and Data
- JTAG interface connector
- One reset pushbutton
- One red user LED
- TDK ICM 42688-P 6-Axis 32KHz IMU
- TDK ICP-10111 Pressure Sensor
- TDK NTC Thermistor for Temperature
- AKM AK09918C Magnetometer
- 2 TDK HVCi-4223 Cortex-M3 Dedicated Motor Controller
- 3 TDK ICS-43434 Stereo Microphones
- Connector for Industrial Dual IMU (TDK IIM-46230)
- TDK CH101 Ultrasonic Range Sensor Array (9 Connectors, comes with 3)

Supported Features
==================

The TDK RoboKit1 board supports the following hardware
features:

.. list-table::
   : header-rows: 1

   * - Peripheral
     - Kconfig option
     - Devicetree compatible
   * - GPIO
     - :kconfig:option:`CONFIG_GPIO_SAM`
     - :dtcompatible:`atmel,sam-gpio`
   * - USART
     - :kconfig:option:`CONFIG_USART_SAM`
     - :dtcompatible:`atmel,sam-usart`
   * - UART
     - :kconfig:option:`CONFIG_UART_SAM`
     - :dtcompatible:`atmel,sam-uart`
   * - SPI
     - :kconfig:option:`CONFIG_SPI_SAM`
     - :dtcompatible:`atmel,sam-spi`
   * - I2C
     - :kconfig:option:`CONFIG_I2C_SAM_TWIHS`
     - :dtcompatible:`atmel,sam-i2c-twihs`
   * - I2S
     - :kconfig:option:`CONFIG_I2S_SAM_SSC`
     - :dtcompatible:`atmel,sam-ssc`
   * - ADC
     - :kconfig:option:`CONFIG_ADC_SAM_AFEC`
     - :dtcompatible:`atmel,sam-afec`
   * - DAC
     - :kconfig:option:`CONFIG_DAC_SAM`
     - :dtcompatible:`atmel,sam-dac`
   * - PWM
     - :kconfig:option:`CONFIG_PWM_SAM`
     - :dtcompatible:`atmel,sam-pwm`
   * - CAN
     - :kconfig:option:`CONFIG_CAN_SAM`
     - :dtcompatible:`atmel,sam-can`
   * - USB
     - :kconfig:option:`CONFIG_USB_DC_SAM_USBHS`
     - :dtcompatible:`atmel,sam-usbhs`
   * - WATCHDOG
     - :kconfig:option:`CONFIG_WDT_SAM`
     - :dtcompatible:`atmel,sam-watchdog`
   * - NVIC
     - N/A
     - :dtcompatible:`arm,v7m-nvic`
   * - SYSTICK
     - N/A
     - N/A
   * - COUNTER
     - :kconfig:option:`CONFIG_COUNTER_SAM_TC`
     - :dtcompatible:`atmel,sam-tc`
   * - DMA
     - :kconfig:option:`CONFIG_DMA_SAM_XDMAC`
     - :dtcompatible:`atmel,sam-xdmac`
   * - ENTROPY
     - :kconfig:option:`CONFIG_ENTROPY_SAM_RNG`
     - :dtcompatible:`atmel,sam-trng`
   * - HWINFO (reset cause)
     - :kconfig:option:`CONFIG_HWINFO_SAM_RSTC`
     - :dtcompatible:`atmel,sam-rstc`
   * - HWINFO (device id)
     - :kconfig:option:`CONFIG_HWINFO_SAM`
     - N/A

The default configuration can be found in the Kconfig
:zephyr_file:`boards/tdk/robokit1/robokit1_defconfig`.

Connections and IOs
===================

The TDK RoboKit Hardware Guide has detailed information about board connections.

System Clock
============

The SAM E70 MCU is configured to use the 12 MHz external oscillator on the board
with the on-chip PLL to generate a 300 MHz system clock.

Serial Port
===========

The ATSAME70Q21 MCU has five UARTs and three USARTs. One of the UARTs is
configured for the console and is available as a Virtual COM Port via the USB2 connector.

Programming and Debugging
*************************

Flashing the Zephyr project onto SAM E70 MCU requires the `OpenOCD tool`_.
Both west flash and west debug commands should correctly work with both USB0 and USB1
connected and the board powered.

Flashing
========

#. Run your favorite terminal program to listen for output. Under Linux the
   terminal should be :code:`/dev/ttyACM0`. For example:

   .. code-block:: console

      $ minicom -D /dev/ttyUSB0 -o

   The -o option tells minicom not to send the modem initialization
   string. Connection should be configured as follows:

   - Speed: 115200
   - Data: 8 bits
   - Parity: None
   - Stop bits: 1

#. Connect the TDK RoboKit1 board to your host computer using the
   USB debug port (USB1), USB2 for a serial console, and remaining micro USB for
   power. Then build and flash the :ref:`hello_world` application.

   .. zephyr-app-commands::
      :zephyr-app: samples/hello_world
      :board: robokit1
      :goals: build flash

   You should see "Hello World! robokit1" in your terminal.

Debugging
=========

You can debug an application in the usual way.  Here is an example for the
:ref:`hello_world` application.

.. zephyr-app-commands::
   :zephyr-app: samples/hello_world
   :board: robokit1
   :maybe-skip-config:
   :goals: debug

References
**********

TDK RoboKit1 Product Page:
    https://invensense.tdk.com/products/robokit1-dk/

.. _OpenOCD tool:
    http://openocd.org/
Part 3
한국어 전문 번역
개요
TDK RoboKit1은 주로 ROS2와 함께 사용하는 개발 보드이며, ultrasonic obstacle detection 같은 time-of-flight 측정을 위한 chirp sensor를 포함해 소형 지상 robot에 유용한 많은 sensor를 제공합니다. 300MHz Cortex-M7 ATSAME70Q21, TDK sensor array와 robotics용 pin header를 결합합니다.
하드웨어
- ATSAME70Q21 Cortex-M7 processor
- 12MHz crystal oscillator (원문 표기 Pres)
- 32.768kHz crystal oscillator
- Micro-AB USB device
- CMSIS-DAP·VCP·Data를 지원하는 Micro-AB USB debug Microchip EDBG
- JTAG connector
- reset pushbutton 1개
- red user LED 1개
- TDK ICM-42688-P 6-axis 32kHz IMU
- TDK ICP-10111 pressure sensor
- TDK NTC thermistor
- AKM AK09918C magnetometer
- TDK HVCi-4223 Cortex-M3 dedicated motor controller 2개
- TDK ICS-43434 stereo microphone 3개
- TDK IIM-46230 industrial dual IMU connector
- TDK CH101 ultrasonic range sensor connector 9개, sensor 3개 포함
Zephyr 지원 기능
| Peripheral | Kconfig option | Devicetree compatible |
|---|---|---|
| GPIO | CONFIG_GPIO_SAM | atmel,sam-gpio |
| USART | CONFIG_USART_SAM | atmel,sam-usart |
| UART | CONFIG_UART_SAM | atmel,sam-uart |
| SPI | CONFIG_SPI_SAM | atmel,sam-spi |
| I2C | CONFIG_I2C_SAM_TWIHS | atmel,sam-i2c-twihs |
| I2S | CONFIG_I2S_SAM_SSC | atmel,sam-ssc |
| ADC | CONFIG_ADC_SAM_AFEC | atmel,sam-afec |
| DAC | CONFIG_DAC_SAM | atmel,sam-dac |
| PWM | CONFIG_PWM_SAM | atmel,sam-pwm |
| CAN | CONFIG_CAN_SAM | atmel,sam-can |
| USB | CONFIG_USB_DC_SAM_USBHS | atmel,sam-usbhs |
| WATCHDOG | CONFIG_WDT_SAM | atmel,sam-watchdog |
| NVIC | N/A | arm,v7m-nvic |
| SYSTICK | N/A | N/A |
| COUNTER | CONFIG_COUNTER_SAM_TC | atmel,sam-tc |
| DMA | CONFIG_DMA_SAM_XDMAC | atmel,sam-xdmac |
| ENTROPY | CONFIG_ENTROPY_SAM_RNG | atmel,sam-trng |
| HWINFO (reset cause) | CONFIG_HWINFO_SAM_RSTC | atmel,sam-rstc |
| HWINFO (device id) | CONFIG_HWINFO_SAM | N/A |
기본 설정은 boards/tdk/robokit1/robokit1_defconfig입니다.
연결과 I/O
board connection의 자세한 정보는 TDK RoboKit Hardware Guide를 참조합니다.
System clock
SAM E70은 board의 external 12MHz oscillator와 on-chip PLL로 300MHz system clock을 생성합니다.
Serial port
ATSAME70Q21에는 UART 5개와 USART 3개가 있습니다. UART 하나가 console로 설정되어 USB2 connector의 VCP로 제공됩니다.
프로그래밍과 디버깅
SAM E70에 Zephyr를 flash하려면 OpenOCD가 필요합니다. USB0·USB1을 모두 연결하고 board에 전원을 공급하면 west flash와 west debug가 동작합니다.
Flash 절차
terminal을 열어 출력을 수신합니다. 설명은 Linux terminal을
/dev/ttyACM0이라고 하지만 원문 예시 명령은/dev/ttyUSB0을 사용합니다.$ minicom -D /dev/ttyUSB0 -o-o는 modem initialization string을 보내지 않게 합니다. 연결 설정은 115200 baud, data 8-bit, parity none, stop bit 1입니다.USB debug port USB1, serial console용 USB2, 전원용 나머지 micro USB를 host에 연결합니다. 그다음 hello_world를 build·flash합니다.
west build -b robokit1 samples/hello_world
west flash
terminal에
Hello World! robokit1이 표시되어야 합니다.
Debug
west build -b robokit1 samples/hello_world
west debug
참고 자료
Source
출처
영어 원문에는 문단, 문서 지시문, 표, 코드, 코드 심벌, 경로를 그대로 보존했습니다.