Part 1
요약·해설
지원 UART/GPIO, SRAM-only Zephyr port, SWD와 GDB 연결 흐름을 설명합니다.
QuickLogic EOS S3
MC3635 · DPS310 · IM69D130
OpenOCD or J-Link · GDB
Part 2
접을 수 있는 영어 원문 전체
영어 원문 전체 펼치기
41F7AADF837E383EA7FE44DC3CA7FD55EF2502C87CC78B2EF22B52109AF84018
.. _quickfeather:

QuickFeather
############

Overview
********

The QuickFeather development board is a platform with an on-board QuickLogic
EOS S3 Sensor Processing Platform.


.. figure:: ../../../../../../../boards/quicklogic/quick_feather/doc/img/feather-board.jpg
   :align: center
   :alt: QuickFeather

   QuickFeather (Credit: QuickLogic)

Hardware
********

- QuickLogic EOS S3 MCU Platform
- mCube MC3635 accelerometer
- Infineon DPS310 pressure sensor
- Infineon IM69D130 MEMS microphone
- 16 Mbit of on-board flash memory
- User button
- RGB LED
- Integrated battery charger

Detailed information about the board can be found in a `QuickFeather repository`_.

Supported Features
==================

The QuickFeather configuration supports the following hardware
features:

+-----------+------------+-------------------------------------+
| Interface | Controller | Driver/Component                    |
+===========+============+=====================================+
| UART      | on-chip    | serial port                         |
+-----------+------------+-------------------------------------+
| GPIO      | on-chip    | gpio                                |
+-----------+------------+-------------------------------------+

The default configuration can be found in
:zephyr_file:`boards/quicklogic/quick_feather/quick_feather_defconfig`.

Connections and IOs
===================

Detailed information about pinouts is available in the `schematics document`_.

Programming and Debugging
*************************

Flashing
========

The QuickFeather platform by default boots from flash. Currently
the Zephyr port only enables loading the program directly to SRAM using either
OpenOCD and a SWD programmer or SEGGER JLink.

OpenOCD
-------

In order to connect to the target a SWD programmer supported in
OpenOCD is needed. To connect to the board run:

.. code-block:: console

   openocd -f /path/to/swd-programmer.cfg -f tcl/board/quicklogic_quickfeather.cfg -c "init" -c "reset halt"

`The QuickFeather OpenOCD config`_ can be found in the OpenOCD mainline repository.

JLink
-----

To connect to the QuickFeather board with JLink please follow instructions
in the `QuickFeather User Guide`_.

Debugging
=========

To debug the QuickFeather board please connect to the target with either
OpenOCD or JLink and use GDB distributed in Zephyr's SDK in *arm-zephyr-eabi/bin*
directory.

To load basic sample via GDB:

- Build the sample in an usual way:

.. zephyr-app-commands::
   :zephyr-app: samples/hello_world
   :board: quick_feather
   :goals: build

- Connect to the target using either OpenOCD or JLink
- Connect via GDB and load an ELF file:

.. code-block:: console

   /path/to/zephyr-sdk/arm-zephyr-eabi/bin/arm-zephyr-eabi-gdb
   target remote <port_number>
   file </path/to/zephyr.elf>
   load
   continue

References
**********

.. target-notes::

.. _QuickFeather repository:
    https://github.com/QuickLogic-Corp/quick-feather-dev-board

.. _schematics document:
    https://github.com/QuickLogic-Corp/quick-feather-dev-board/blob/master/doc/quickfeather-board.pdf

.. _The QuickFeather OpenOCD config:
    https://sourceforge.net/p/openocd/code/ci/master/tree/tcl/board/quicklogic_quickfeather.cfg

.. _QuickFeather User Guide:
    https://github.com/QuickLogic-Corp/quick-feather-dev-board/blob/master/doc/QuickFeather_UserGuide.pdf
Part 3
한국어 전문 번역
개요
QuickFeather development board는 on-board QuickLogic EOS S3 Sensor Processing Platform을 갖춘 보드입니다.
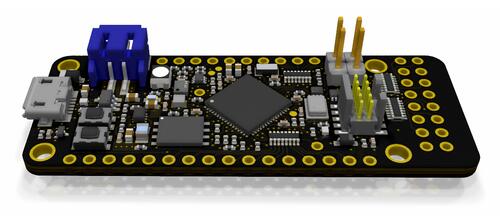
하드웨어
- QuickLogic EOS S3 MCU platform
- mCube
MC3635accelerometer - Infineon
DPS310pressure sensor - Infineon
IM69D130MEMS microphone - On-board flash memory 16Mbit
- User button
- RGB LED
- Integrated battery charger
자세한 내용은 QuickFeather repository에 있습니다.
지원 기능
| 인터페이스 | 컨트롤러 | 드라이버/컴포넌트 |
|---|---|---|
UART | on-chip | serial port |
GPIO | on-chip | gpio |
기본 구성은 boards/quicklogic/quick_feather/quick_feather_defconfig입니다.
연결과 I/O
Pinout은 schematic document에 있습니다.
프로그래밍과 디버깅
Flash
QuickFeather platform은 기본적으로 flash에서 boot합니다. 그러나 현재 Zephyr port는 OpenOCD와 SWD programmer 또는 SEGGER J-Link를 사용해 program을 SRAM에 직접 적재하는 방식만 활성화합니다.
OpenOCD
OpenOCD가 지원하는 SWD programmer를 준비하고 다음처럼 연결합니다.
openocd -f /path/to/swd-programmer.cfg -f tcl/board/quicklogic_quickfeather.cfg -c "init" -c "reset halt"QuickFeather OpenOCD config는 OpenOCD mainline repository에 있습니다.
J-Link
J-Link 연결은 QuickFeather User Guide를 따릅니다.
Debug
OpenOCD 또는 J-Link로 target에 연결하고 Zephyr SDK의 arm-zephyr-eabi/bin directory에 포함된 GDB를 사용합니다. 먼저 hello_world를 build합니다.
# Zephyr 저장소 루트에서
west build -b quick_feather samples/hello_world
Target 연결 뒤 GDB에서 ELF를 load하고 계속 실행합니다.
/path/to/zephyr-sdk/arm-zephyr-eabi/bin/arm-zephyr-eabi-gdb
target remote <port_number>
file </path/to/zephyr.elf>
load
continue
Source
출처
영어 원문에는 문단, 문서 지시문, 표, 코드, 코드 심벌, 경로를 그대로 보존했습니다.